November 2023 - February 2024 (10th Grade)
- Patent Pending - Application number 18/586424 - METHODS, SYSTEMS, APPARATUSES, AND DEVICES FOR FACILITATING INDEPENDENT MANIPULATION OF OBJECTS
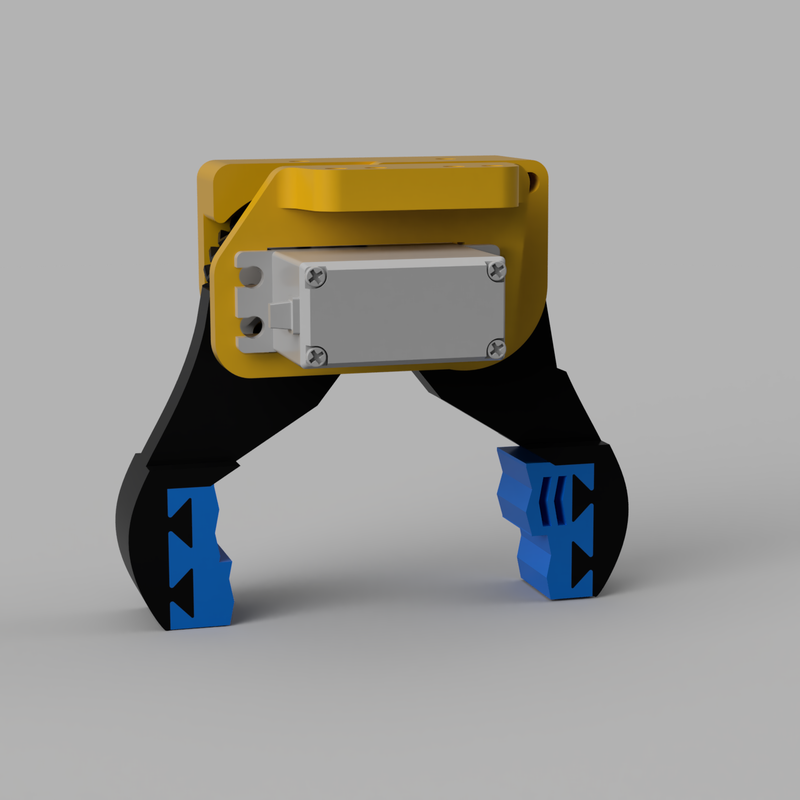
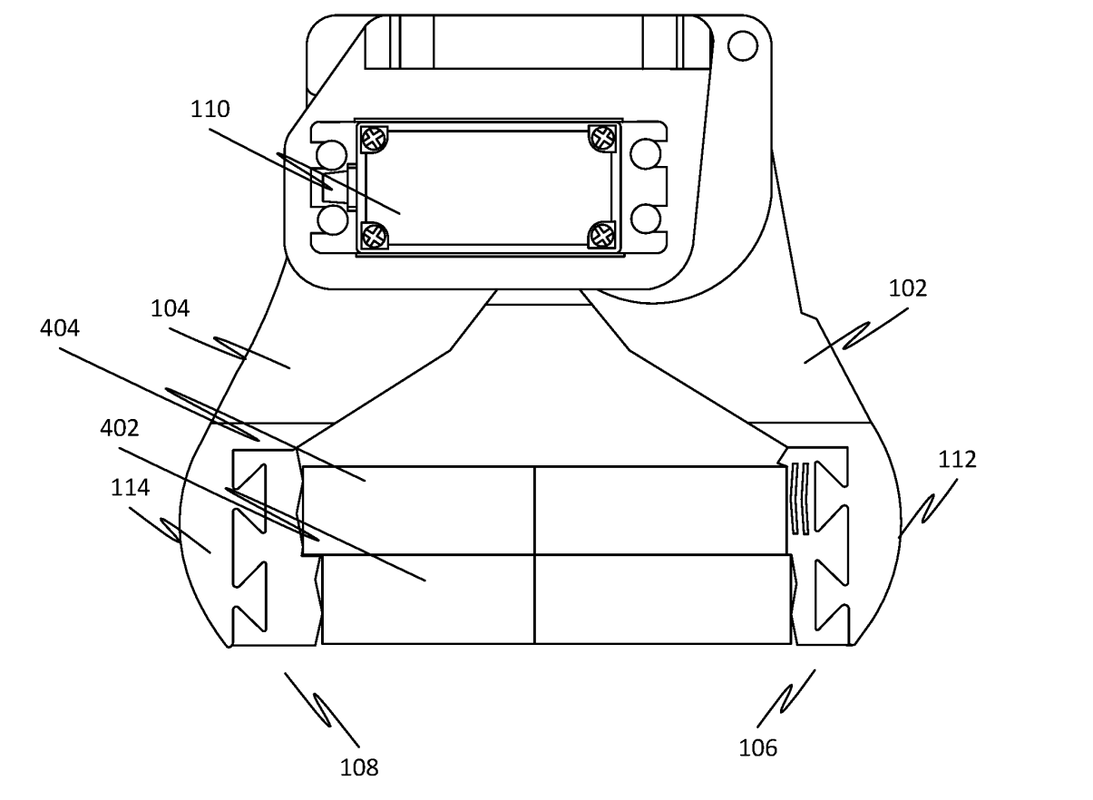
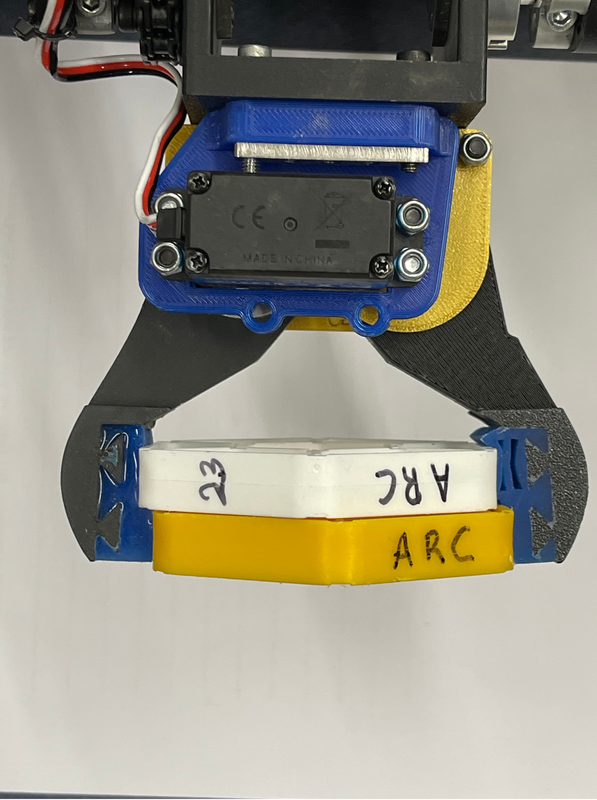
- The gripper is able to hold two stacked objects at the same time and release them independently, using only a single actuator.
- This mechanism can nearly double the efficiency of warehouse automation by eliminating the need for a return movement to pick up a second item, significantly reducing cycle time, with an extremely low cost and little complexity.
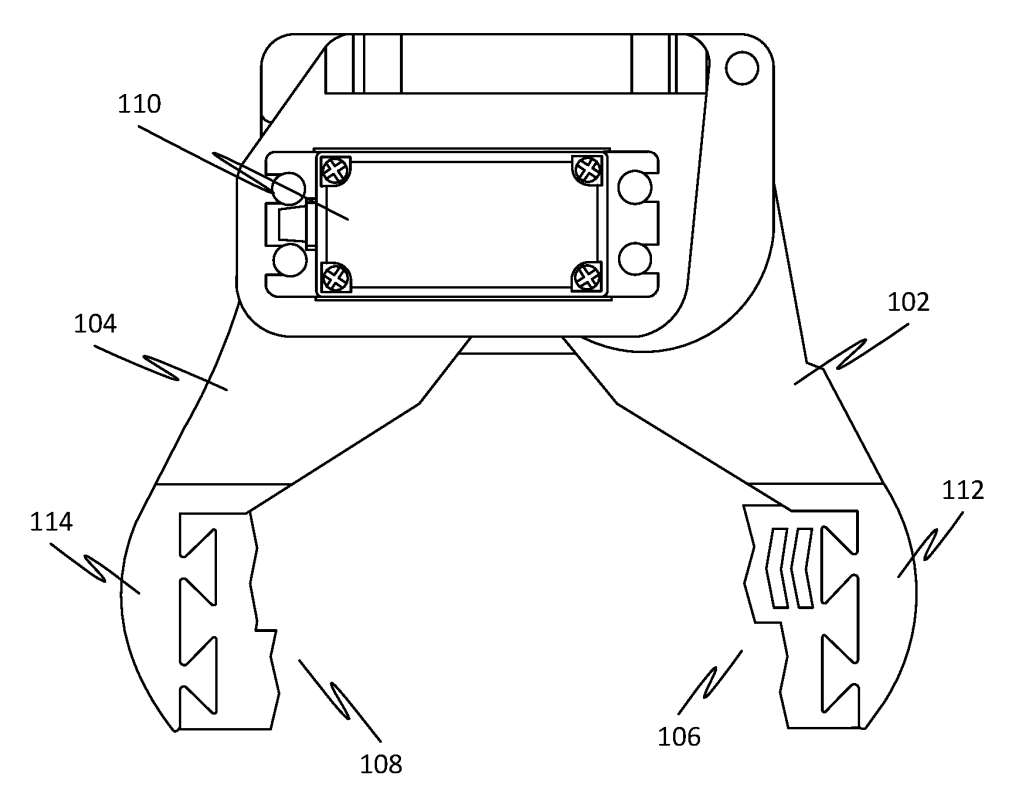
- The gripper has two arms, one powered by a servo actuator, and an idle arm, geared to move in the opposite direction.
- Uses a soft robotic mechanism on the arms of the gripper made of compliant silicone.
- The powered arm incorporates a solid silicone lining(108), with an offset, sticking out where the bottom object would be, facilitating easy object grasping.
- The idle arm also possesses a silicone lining(106), with one segment being solid and less compressible, where the lower object being picked up would be, and a wider compressible section, where the upper object would be, with molded gaps, enabling it to collapse into itself.
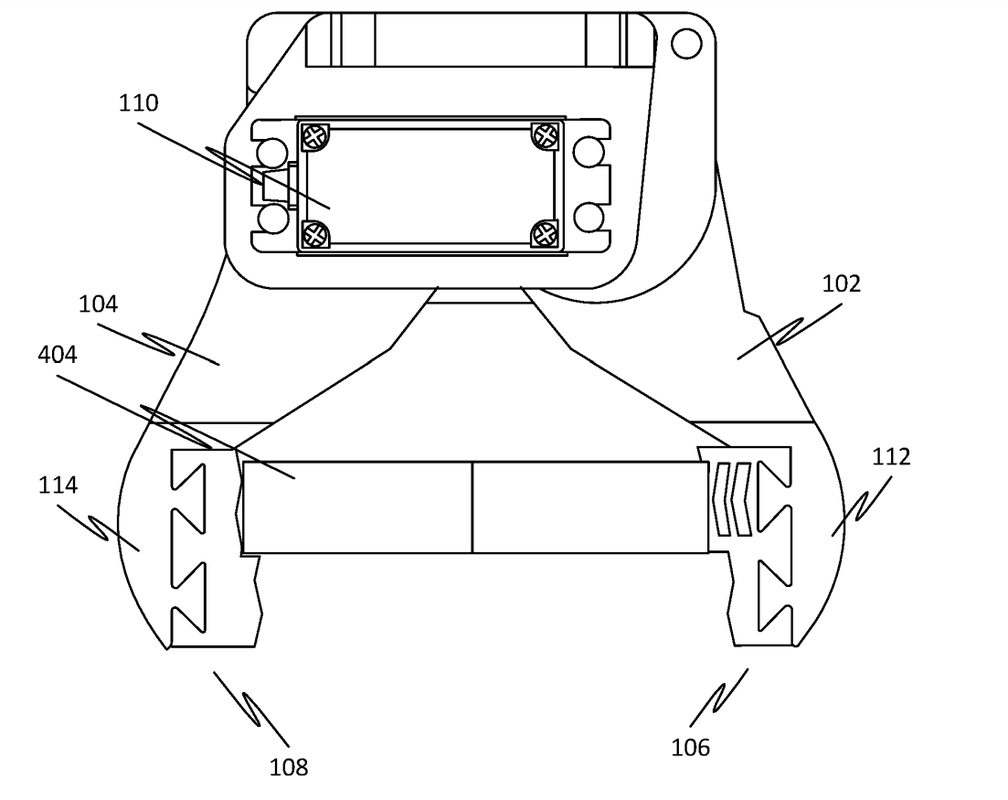
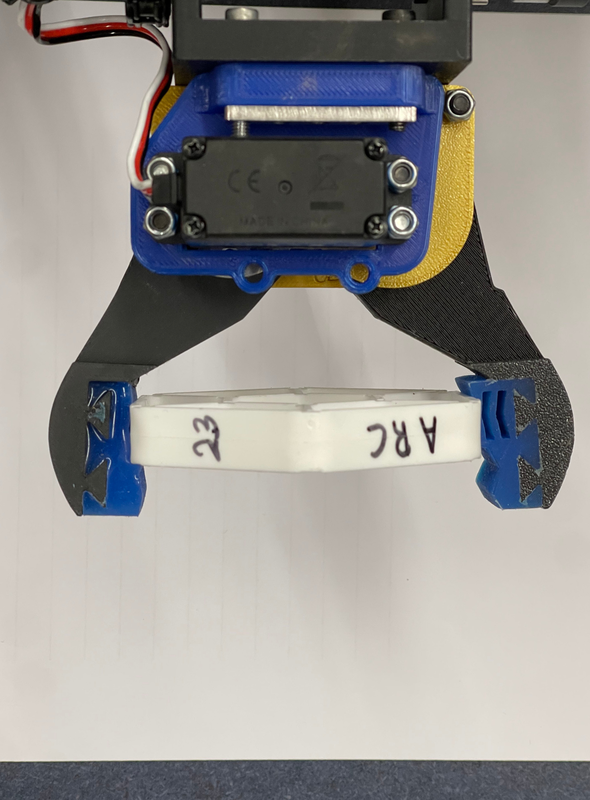
- The gripper can be fully closed to pick up both objects, and when slightly opened, the lower object will drop, but the compressible silicone will act as a spring, gripping the upper object.
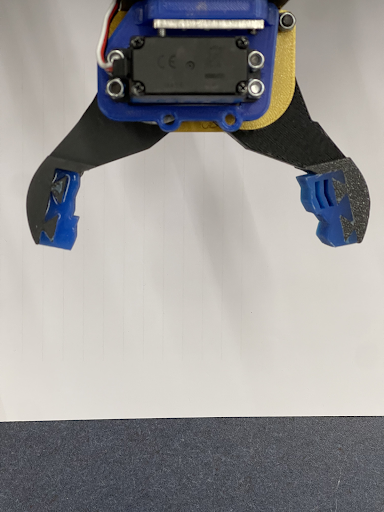
- Opening the gripper fully will drop the upper object.
- Went through 16 iterations.
- Extremely low in cost and complexity, with only 2 moving parts and 5 parts in total.
- Easily scalable & modifiable for different objects.